
An open-source, full-stack self-driving golf cart: perception, planning, control, firmware, and hardware.


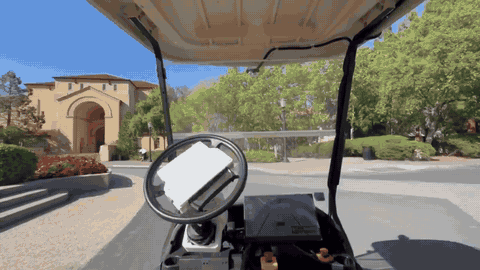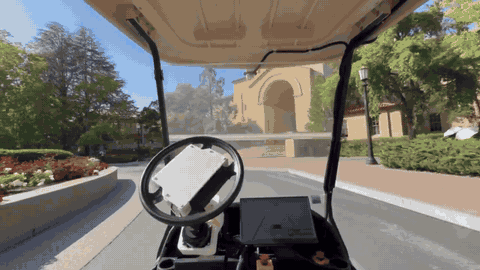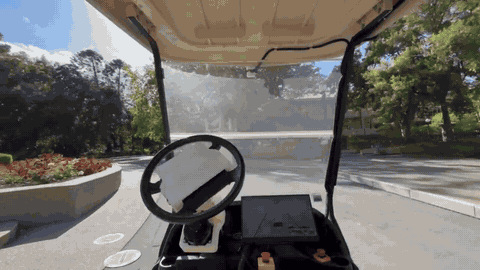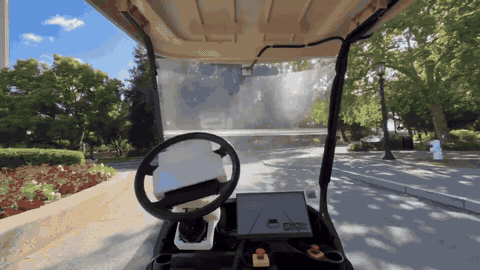
The cart driving itself through Stanford campus. Nobody touches the wheel.
Architecture · Quick start · Drive the cart · Hardware · Safety
This project turns a standard electric golf cart into a self-driving vehicle using off-the-shelf parts: an NVIDIA Jetson for compute, an ODrive-driven steering column, linear actuators on the pedals, an RTK GNSS receiver, and cameras.
The cart's driving policies live in policies/. The two
stacks share one hardware API:
🛰️ Drive by RTKFollow waypoints with centimeter-level RTK GPS. Draw lanes on a map, pick a route in the web UI, press Drive, and a pure-pursuit controller steers the cart along it. |
Drive from a camera alone. SegFormer segments the road, the drivable area is projected into a bird's-eye view, and a lane-aware planner outputs a trajectory and steering angle. |
⚙️ cart-api · |
|
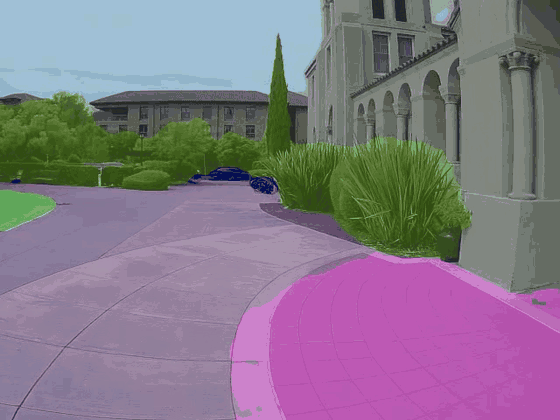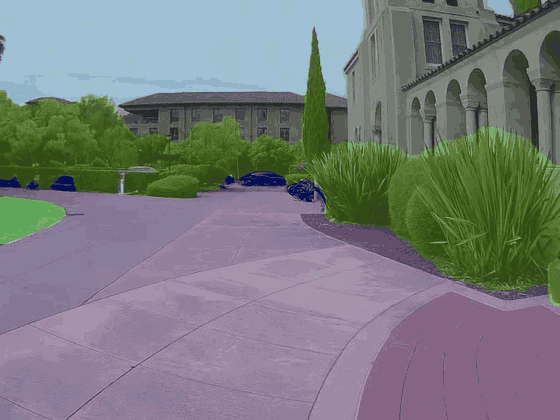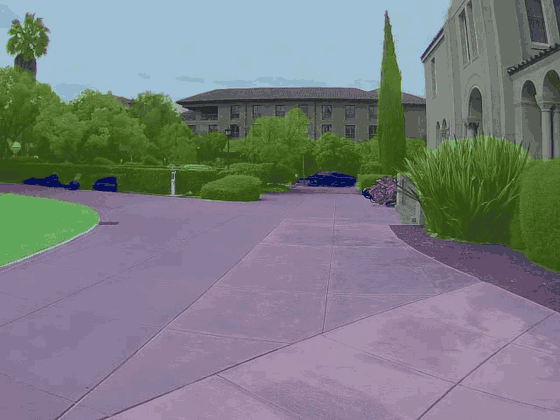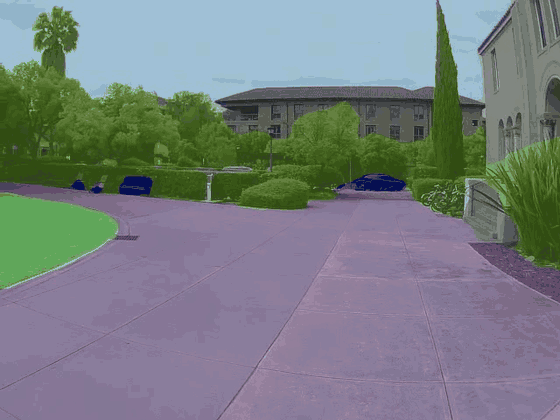
Drive by Segmentation: SegFormer road mask (purple) on campus footage
            ┌──────────────────────────┐        ┌──────────────────────────────┐
            │       policies/rtk       │        │    policies/segmentation     │
            │ map UI · route graph ·   │        │ SegFormer · BEV projection · │
            │ pure-pursuit follower    │        │ lane-aware planner           │
            └────────────┬─────────────┘        └──────────────┬───────────────┘
                         │   steer_deg · gas · brake           │
                         └──────────────────┬──────────────────┘
                                            ▼
                    ┌─────────────────────────────────────────────┐
                    │            cart-api  (cartlib)              │
                    │  Cart · GpsReceiver · NtripClient ·         │
                    │  SteeringController · PedalController       │
                    └──────┬─────────────────┬─────────────────┬──┘
                    USB-CDC│ ODrive ASCII    │ serial G/B/S/H/D│ NMEA / RTCM
                           ▼                 ▼                 ▼
                    ┌─────────────┐   ┌──────────────┐  ┌──────────────┐
                    │  ODrive S1  │   │ Arduino Mega │  │ u-blox ZED-F9│
                    │  + M8325s   │   │ pedal fw +   │  │ RTK receiver │
                    │  steering   │   │ watchdog     │  │ + NTRIP      │
                    └─────────────┘   └──────┬───────┘  └──────────────┘
                                             ▼
                                   gas + brake actuators
                                   (hardware e-stop loop)
Compute runs on an NVIDIA Jetson AGX Thor. Development also works on a laptop.
Deeper notes live in docs/architecture.md.
git clone https://github.com/autonomous-golf-cart/autonomous-golf-cart.git
cd autonomous-golf-cart

# 1. Install the cart API
pip install -e "cart-api[server]"

# 2. Check the hardware (read-only, nothing moves)
./cart-api/cart test
[GPS] fix=GPS sats=12 hdop=0.54 lat=37.426562 lon=-122.164102 PASS
[PEDALS] gas_pot=0.007 brake_pot=0.009 failsafe=True estop=False PASS
[STEERING] bus_voltage=47.5 V angle=-0.01° state=IDLE errors=0 PASS
Drive by RTK
export MAPBOX_TOKEN=pk.your_token
export NTRIP_RTKDATA_USER=...  NTRIP_RTKDATA_PASS=...
./policies/rtk/golive.sh --ntrip          # → http://localhost:3001
Drive by segmentation
pip install -r policies/segmentation/requirements.txt
python policies/segmentation/live.pyThe cart API is how every policy moves the actual cart. These calls turn the steering column and press the pedals on the real vehicle.
from cartlib import Cart

with Cart() as cart:
    cart.arm()                       # GPS streaming, pedals out of failsafe
    print(cart.snapshot())           # live GPS + pedals + steering state

    cart.steering.enable()           # energize steering motor
    cart.steering.set_angle(15)      # +15° at the steering column
    cart.pedals.set_brake(0.2)       # brake (always safe)
cart.stop() # release pedals| Command | What it does |
|---|---|
cart test |
Read-only self-test of all three subsystems |
cart read [--ntrip] |
Live read-only dashboard |
cart record PATH |
Drive manually and record an RTK path |
cart follow PATH |
Preview a path (dry run) |
cart drive PATH --max-speed X |
Drive the path autonomously |
cart serve [--gps-only] |
WebSocket bridge for the map UI (ws://localhost:8765) |
Full reference: cart-api/README.md.
The cart is a Club Car Precedent retrofitted with drive-by-wire steering and pedals. An ODrive S1 controls an M8325s motor through a 3:1 HTD 5M belt drive; a printed chestplate fits over the steering wheel to turn it. Two 12 V linear actuators press the gas and brake, driven by BTS7960 H-bridges and an Arduino Mega with potentiometer feedback.
An onboard Jetson AGX Thor connects to the cameras, IMU, and GNSS receiver. The pictured build carries six cameras, three front and three rear, plus a roof-mounted Starlink Mini for connectivity.
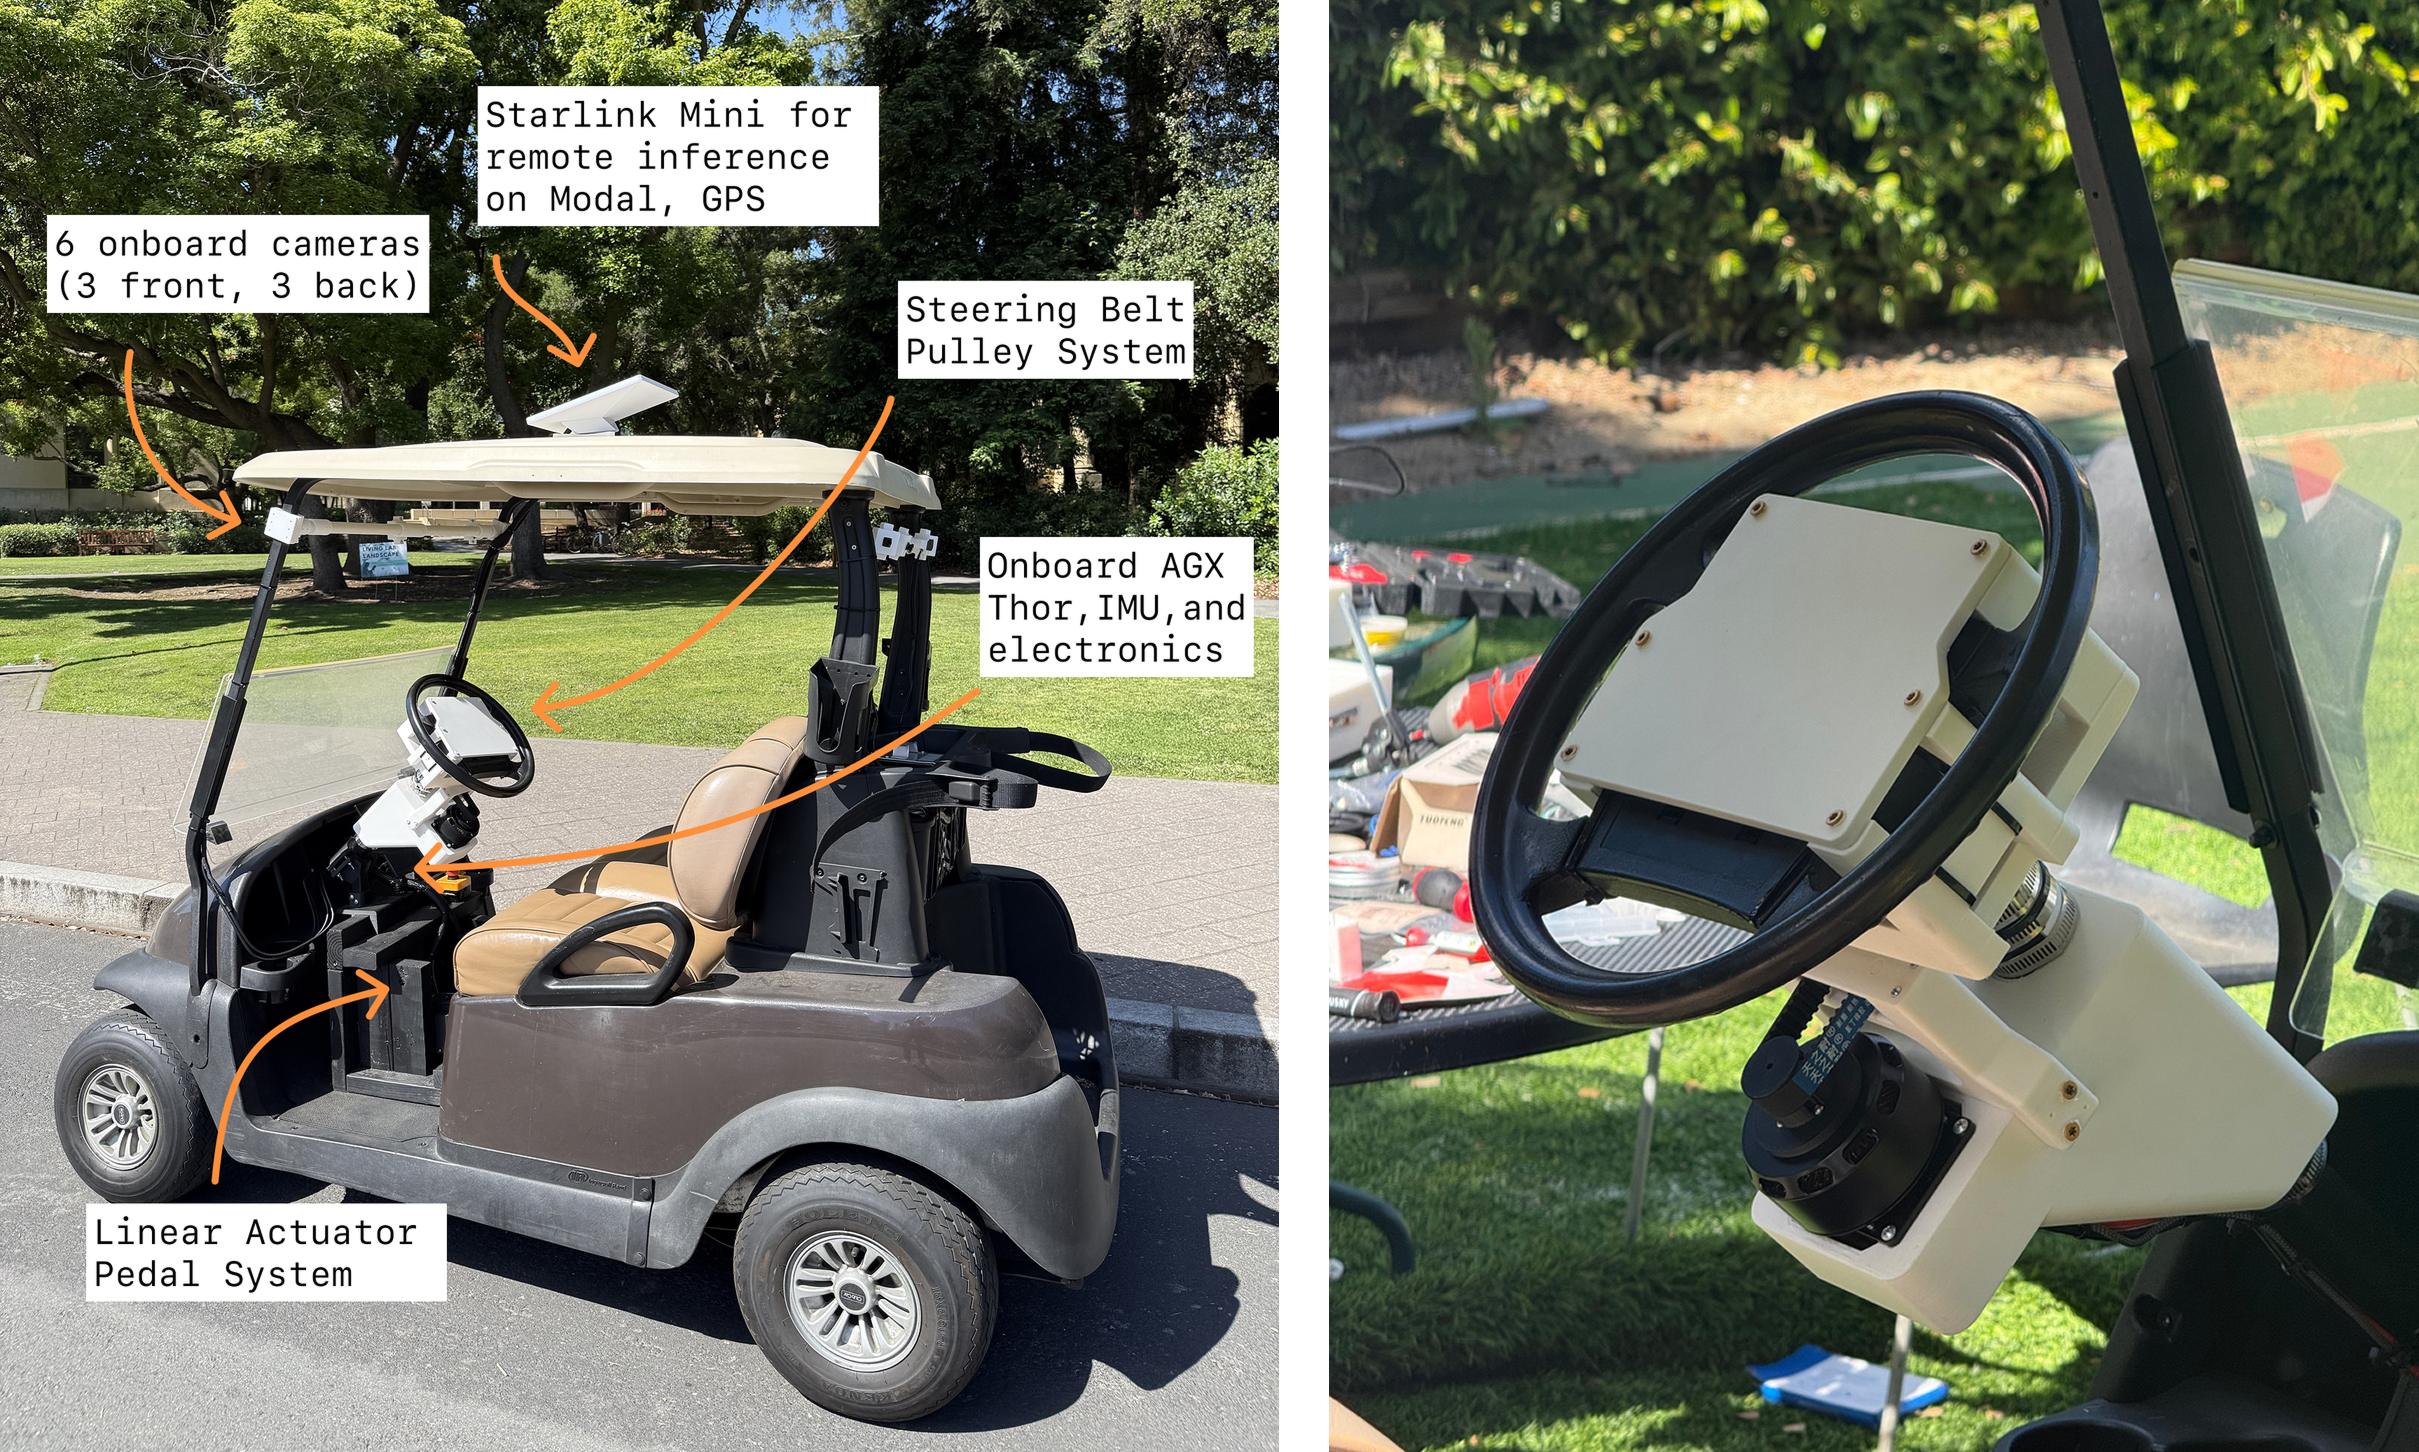
Installed hardware (left) and steering-wheel assembly (right).
| Subsystem | Hardware | Interface |
|---|---|---|
| Compute | NVIDIA Jetson AGX Thor | — |
| Steering | ODrive S1 + M8325s, 3:1 HTD 5M belt | USB · ODrive ASCII |
| Gas + brake | 2× linear actuators, BTS7960 drivers, Arduino Mega 2560 | USB serial |
| Localization | u-blox ZED-F9x RTK GNSS + NTRIP corrections | NMEA / RTCM |
| Vision | Camera rig; six cameras in the pictured build | USB |
| Safety | Hardware e-stop + firmware heartbeat watchdog | — |
The cart includes 33 mechanical 3D-printed components for steering, pedal actuation, camera mounting, sensor housings, and accessories.
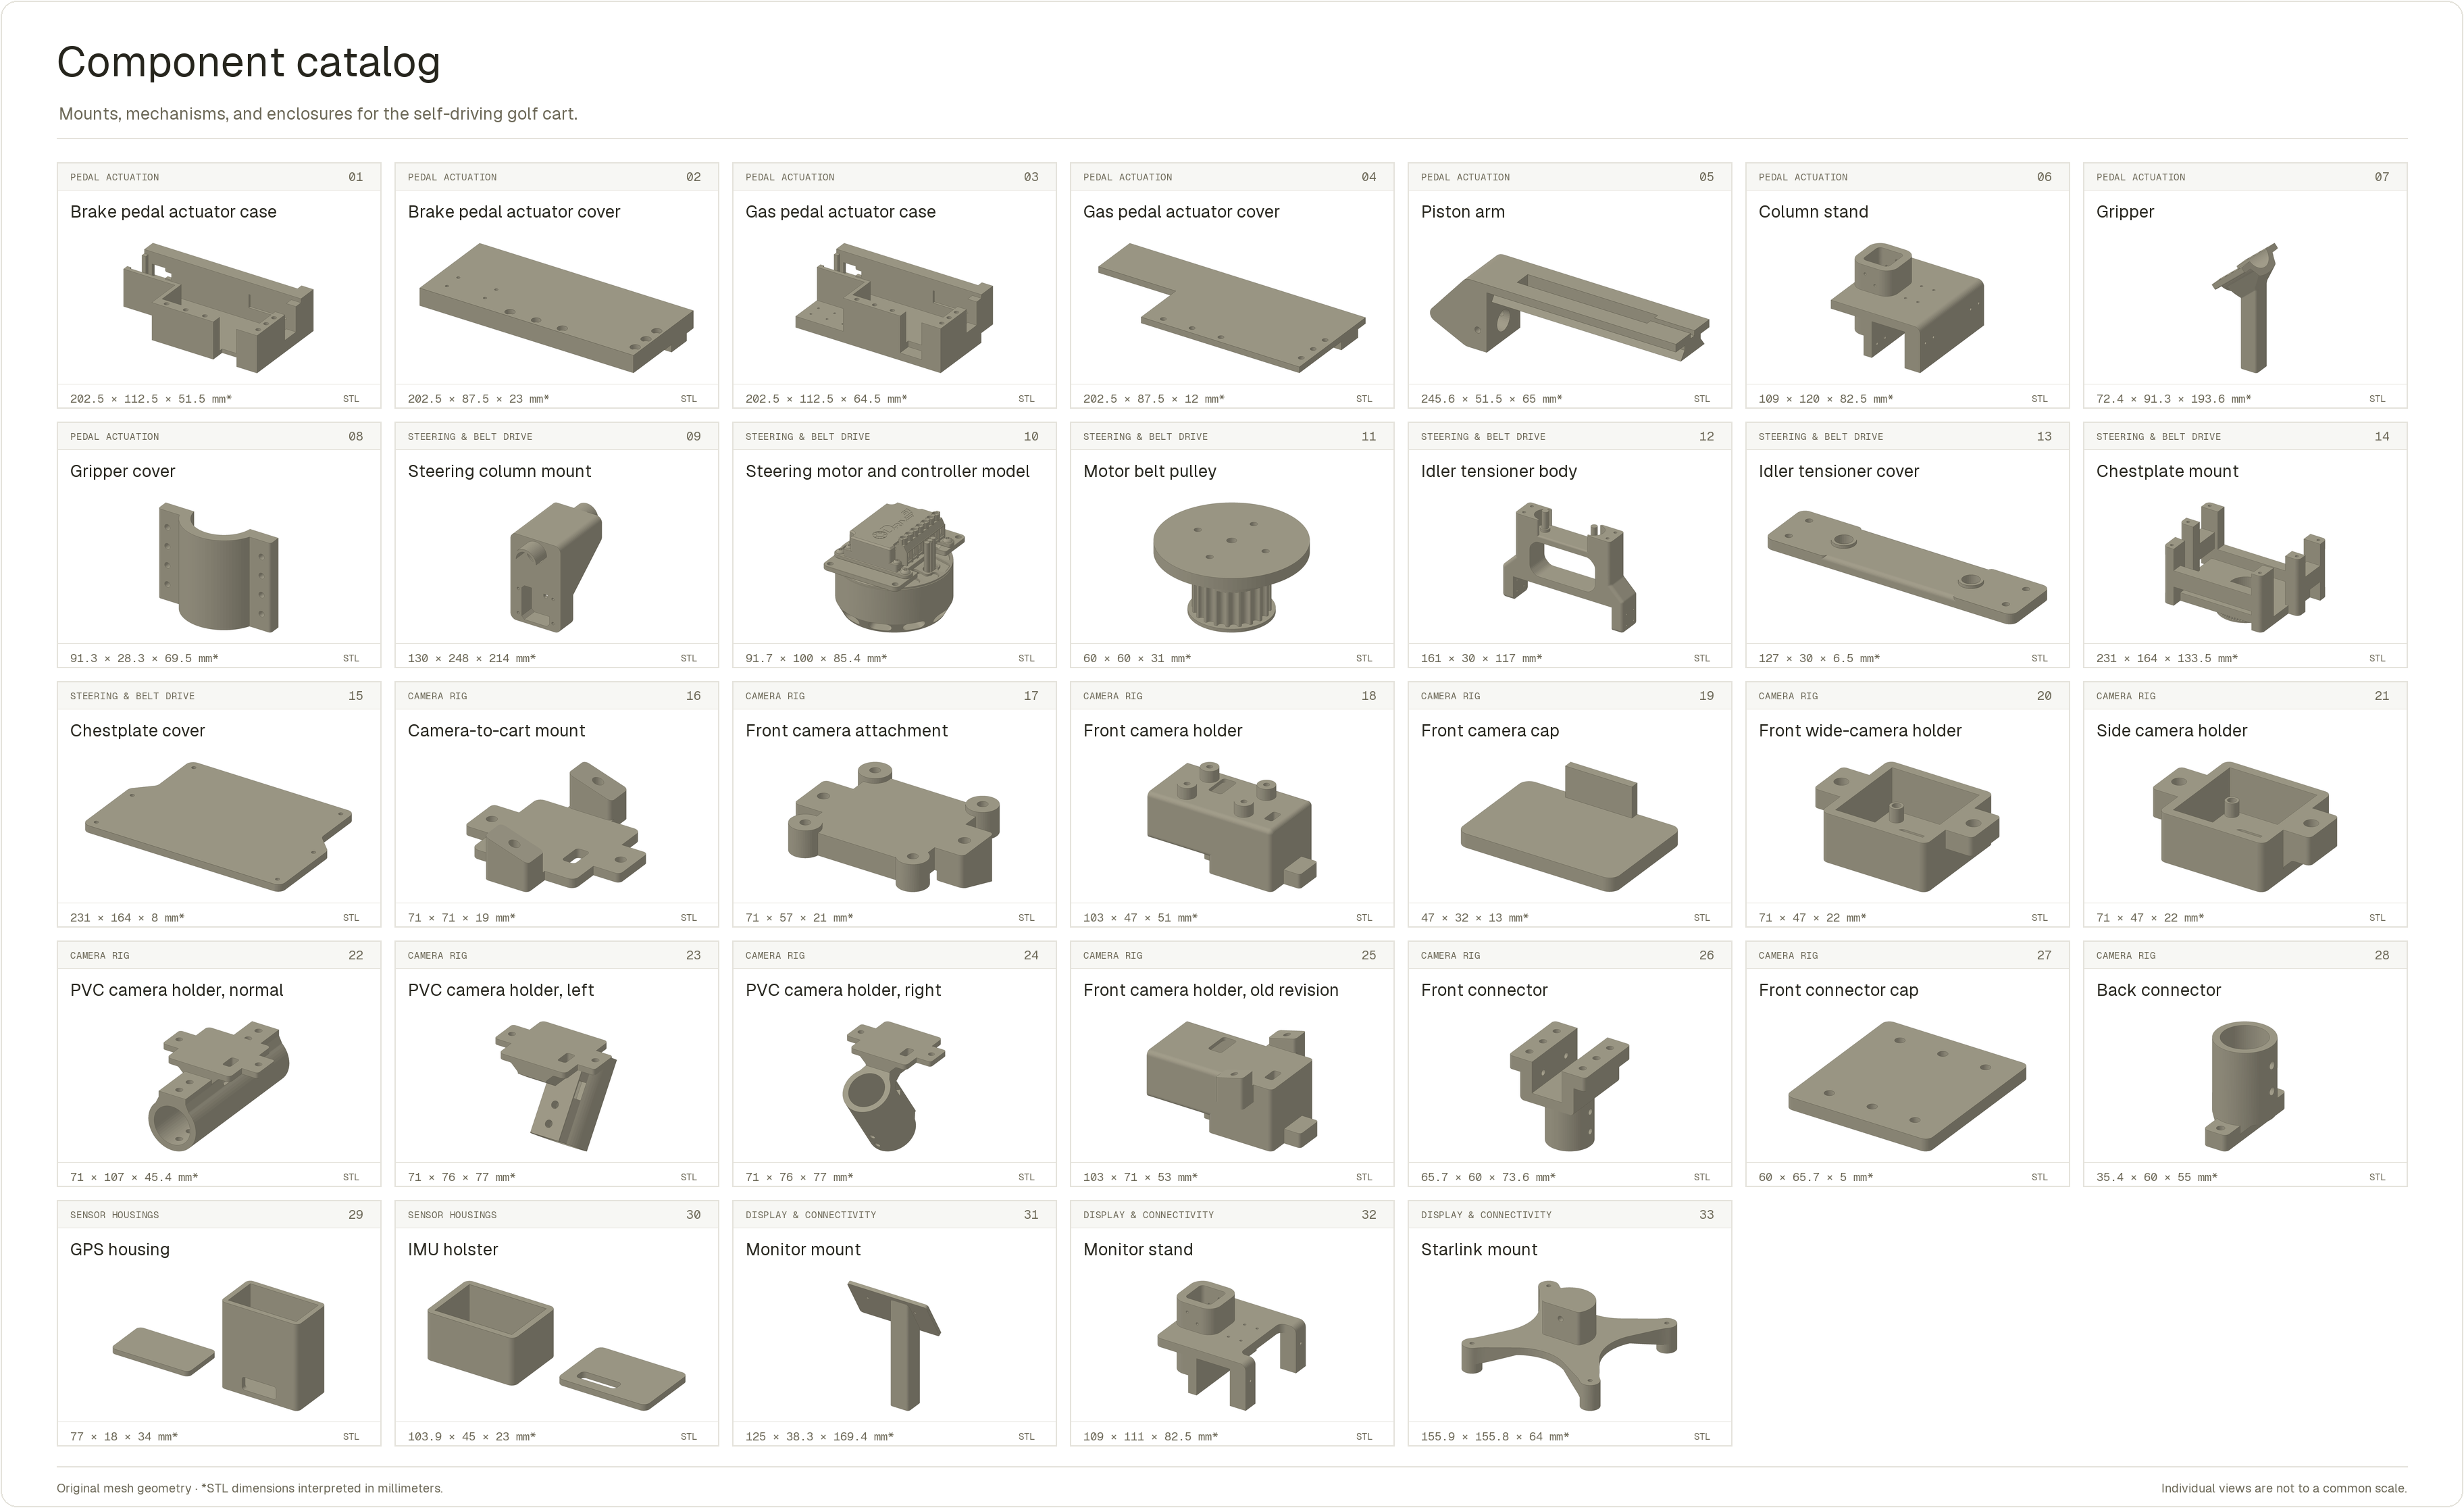
Browse the CAD exports, per-component renders, and installation descriptions in the
hardware catalog. Subsystem write-ups
are in docs/: steering ·
pedal actuators · e-stop ·
GPS · cameras.
Warning
This software moves a real vehicle. Always test in a closed area, at low speed, with a person ready on the hardware e-stop.
- The pedal firmware boots in FAILSAFE and re-enters it (gas released, brake applied) if the host heartbeat stops for more than 300 ms.
- A hardware e-stop forces full brake and zero gas at the firmware level.
- Throttle is capped in layers: hardware pot max → global speed limit → per-mode cap. See
hardware/arduino-sketches/limits.py. - Anything that moves the cart is opt-in. The gas demo additionally requires
--i-understand-this-drives.
Issues and pull requests are welcome.
The hardware and software of this project are fully open source, released under the MIT License.

